Autonomy stack for a coastal survey USV
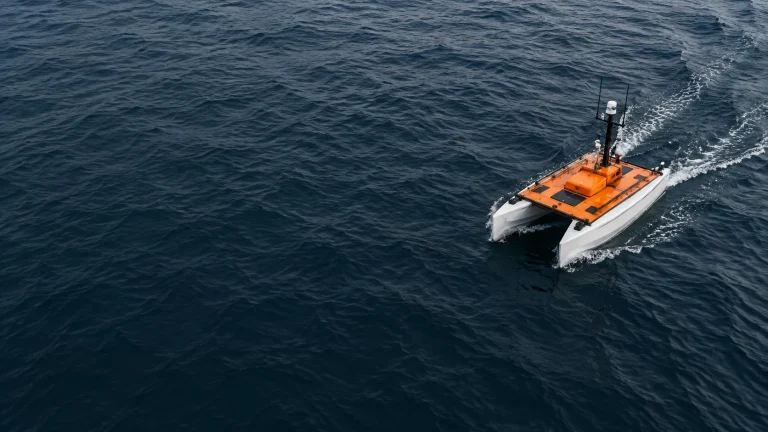
A survey operator wanted a 6 m boat to run bathymetry lines without a helmsman, keeping line spacing inside half a metre in a one metre swell.
We wrote the autopilot, a line planner that accounts for drift, and an operator console that shows one screen per mission phase. Sonar, GNSS and heading feed one state estimator on a small marine computer.
Two problems held us up. Heading data dropped out near steel harbour walls, and the first line planner fought the current instead of leaning into it. We added a compass fallback and rewrote the planner around measured drift.
Line keeping inside 0.4 m at 4 knots. Survey days per project dropped by about a third because the boat runs while the crew processes data.
- C++
- ROS 2
- NMEA 2000
- Qt console
Line keeping inside 0.4 m at 4 knots. Survey days per project dropped by about a third because the boat runs while the crew processes data.